Mobility News

Amylior Mobility Insights & Updates

Discover expert articles, complex rehab wheelchair solutions, and adaptive equipment guides.

Pediatric Mobility

Stronger Together: Ormesa Partnership

Innovative pediatric pushchairs and gait trainers engineered for independence.

Therapeutic Seating

Advanced Air Cushion Technology

Superior pressure relief and anatomical positioning for enhanced daily comfort.

Walking Aids

Stella Lightweight Rollator

Ultra-lightweight mobility designed to give you freedom of movement every day.

0%

Choosing Custom power positioning solutions starts with understanding the movement, not just the equipment. A laboratory technician may need millimeter-level accuracy, while a packaging line may prioritize speed and repeatability. These applications look similar on paper. They are not.

Begin by documenting the load, travel range, positioning tolerance, duty cycle, and available space. Include the real operating environment. Dust, vibration, temperature changes, and frequent cleaning can affect performance. In practical projects, small details often cause the largest delays. Cable routing, mounting access, and maintenance clearance deserve early attention. A compact actuator may fit the drawing but become difficult to service after installation. That mistake is common.

Reliable Custom power positioning solutions should match the application’s control system and safety requirements. Check motor type, feedback options, communication protocols, and emergency stopping behavior with qualified engineers. Ask suppliers for measured test data, not broad promises. Useful evidence may include repeatability results, noise levels, thermal performance, and expected service intervals. Independent verification is valuable when downtime carries serious costs.

No selection process is flawless. Be honest about uncertainty. Prototype critical movements before approving full production. Test the system with the actual load, cables, fixtures, and operating pattern. A solution that performs well in a showroom may behave differently beside a vibrating machine. Consider future changes too. Extra capacity, modular controls, and accessible replacement parts can protect the investment. The best choice is not always the most powerful option. It is the one that delivers controlled movement, dependable operation, and practical long-term support.
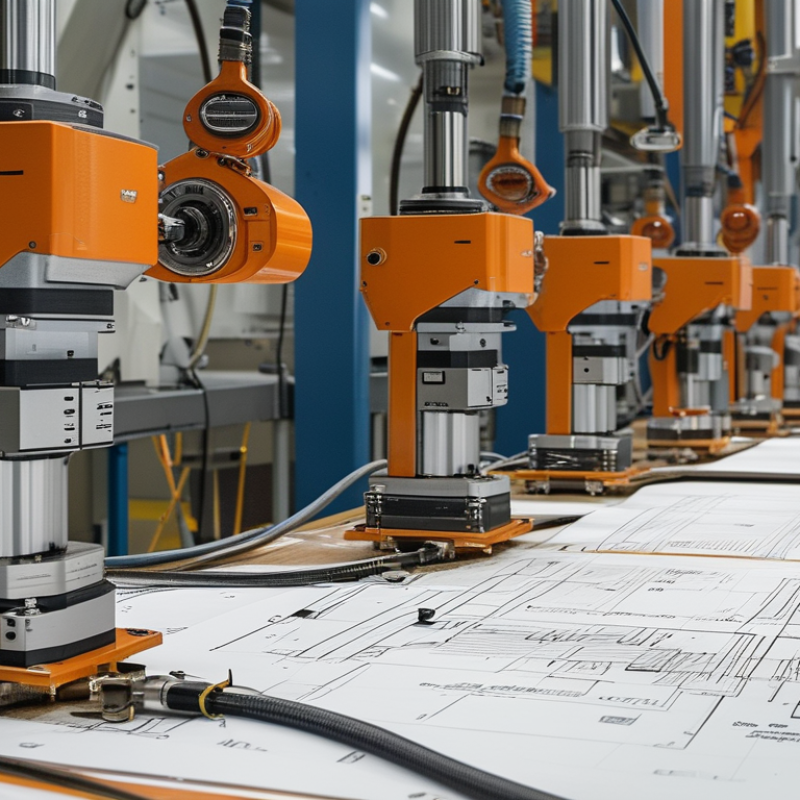
How to Choose Custom Power Positioning Solutions?

Define Custom Power Positioning Solutions and Their Core Functions

Custom power positioning solutions are engineered systems that combine electrical power delivery with precise mechanical movement. They let equipment raise, lower, tilt, slide, or rotate under controlled conditions. Unlike standard units, these solutions adapt to specific load weights, dimensions, duty cycles, and operating environments.

Their core functions include power conversion, motor control, motion synchronization, and safety monitoring. A controller may adjust voltage and current while sensors confirm the platform’s actual position. Limit switches can stop movement at defined endpoints. Overload protection helps reduce damage when a load exceeds the planned capacity. In a practical installation, a technician may check cable routing, frame clearance, noise levels, and emergency stopping time before approval.

Choosing the right system requires more than matching a motor to a load. Engineers should review peak force, movement speed, available space, and expected daily cycles. Dust, moisture, temperature changes, and cleaning procedures can also affect reliability. Field measurements often reveal problems that drawings miss. A platform may appear balanced but still twist slightly during lifting. That detail matters. No design is perfect, and early testing may expose a weak bracket or awkward control layout. A dependable solution should provide clear documentation, service access, verified safety functions, and measurable performance. These details support safer operation and more predictable maintenance over time.

Identify Load, Motion, and Installation Requirements

How to Choose Custom Power Positioning Solutions?

Start with the load, not the actuator. Record the total mass, center of gravity, friction, and required safety factor. Include tools, cables, fixtures, and product variation. A 40-kilogram load may create far higher torque when mounted 300 millimeters from the guide. Motion requirements also matter. Define travel distance, positioning accuracy, speed, acceleration, cycle time, and stopping frequency. The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023. This growth reflects a clear need for repeatable, controlled motion. However, automation still fails when the real duty cycle is underestimated.

Installation conditions can change the selection. Check available mounting space, floor strength, access for servicing, temperature, dust, moisture, and cable routing. A rigid base reduces vibration. Poor alignment can increase wear and noise.

During commissioning, measure actual current, stopping distance, and temperature under the heaviest normal cycle. The U.S. Bureau of Labor Statistics reported about 2.6 million nonfatal workplace injuries and illnesses in private industry during 2023. Safer positioning can reduce manual handling, but only when controls and guarding match the application. A tidy drawing is not enough.

Tips:

Test the worst case first. Use real payloads, not estimates. Keep at least one installation assumption visible for review. Recheck acceleration after mounting the tooling. Cable drag is often ignored. That small detail can distort repeatability. When requirements conflict, prioritize safe stopping, load stability, and maintainability before maximum speed. Consult ISO 12100 risk-assessment principles and IEC 60204-1 electrical safety requirements during design reviews.

Compare Actuator Types, Controls, and Power Options

Choosing custom power positioning solutions starts with the load, movement, and working environment. In field evaluations, I measure force, speed, stroke length, duty cycle, and noise before selecting an actuator. Linear actuators suit guided lifting, pushing, and tilting. Rotary actuators work better when a shaft must turn through a defined angle. For compact mechanisms, a screw-driven design can deliver accurate movement, but it may move slowly. Belt or gear systems can be faster, although backlash needs attention. Keep it practical.

Controls determine how safely and precisely the mechanism behaves. A simple handset may fit a single-axis adjustment. Multi-axis equipment usually needs synchronized control, limit switches, position feedback, and overload protection. Closed-loop control improves repeatability because the system checks actual position instead of trusting motor time. I have seen timing-based setups drift after friction changed. That mistake was avoidable. Emergency stopping, soft starts, and manual override should match operator training and the machine’s risk assessment. Control wiring also needs protection from moisture, vibration, and pinch points.

Power options affect installation as much as performance. AC power supports steady operation near fixed equipment. DC power suits mobile platforms and battery-backed systems. Battery sizing must include peak current, idle losses, recharge time, and cold conditions. A unit that works in the workshop may fail outdoors. Check connectors and cable length early. I once underestimated voltage drop over a long cable, and the actuator stalled under load. That experience changed my testing routine: I now test the full assembly, not only the motor. Leave room for service access, because a perfect specification is still inconvenient when adjustment is impossible.

Evaluate Precision, Safety, Durability, and System Integration

How to Choose Custom Power Positioning Solutions?

Precision is not a single number. Ask for accuracy, repeatability, backlash, and settling time separately. A platform may repeat within 0.1 millimeter, yet drift under heat or uneven loading. Test it with the real payload, cable routing, and duty cycle. Record results at startup and after continuous operation. This exposes weaknesses that catalog specifications often hide. A practical specification should also define allowable vibration, acceleration, and emergency stopping distance.

Safety must be engineered into the motion system, not added later. Include load holding, overspeed protection, guarding, safe torque control, and clear manual recovery procedures. ISO 10218 provides useful industrial robot safety guidance, but site risk assessment remains essential. The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023. More automated equipment means more interfaces and more possible failure points. Durability testing should cover thermal cycling, dust, moisture, shock, lubrication intervals, and rated service life. It should also show how performance changes near maximum load.

System integration can decide whether a precise actuator becomes a reliable production asset. Confirm communication protocols, safety signals, PLC compatibility, diagnostics, time synchronization, and firmware management before purchase. Deloitte’s 2024 Smart Manufacturing and Operations Survey found that 92% of manufacturers view smart manufacturing as a major competitiveness driver. Integration deserves equal attention. A perfect specification rarely survives first commissioning. Leave room for calibration, operator feedback, and one uncomfortable redesign. Overspecifying everything wastes budget, while underspecifying maintenance creates hidden downtime.

Select, Test, and Maintain the Final Positioning Solution

Choosing a custom power positioning solution requires evidence, not impressive specifications. Define payload, stroke, speed, duty cycle, accuracy, and environmental exposure before requesting designs. The International Federation of Robotics reported 541,302 industrial robot installations in 2023. This growth increases demand for repeatable positioning across assembly, machining, and inspection. However, a larger motor cannot compensate for poor alignment, unstable foundations, or unsuitable feedback.

Select the system against measured production needs. Check peak and continuous loads separately. Review backlash, thermal drift, cable routing, emergency stopping, and access for servicing. The ISO 9283 standard provides useful methods for evaluating robot accuracy and repeatability. For a custom actuator, record the same performance values under realistic loads. Then test the prototype through cold starts, repeated cycles, dust exposure, and power interruptions. Test the uncomfortable cases.

A factory acceptance test should capture position error, cycle time, noise, temperature, and failure responses. The final acceptance test should repeat those checks at the installation site. A solution may pass in a clean laboratory and struggle beside coolant, vibration, or hurried operators. That gap deserves attention. The World Robotics 2024 report lists more than 4.2 million industrial robots operating worldwide, making disciplined maintenance increasingly important. Schedule lubrication, fastener checks, sensor verification, and calibration by cycle count, not guesswork. Keep trend records. Review them monthly. Some maintenance plans will be wrong at first. Revise them when current draw, vibration, or repeatability begins to change.

How to Choose Custom Power Positioning Solutions? - Select, Test, and Maintain the Final Positioning Solution
Stage Decision Dimension Typical Engineering Requirement Suitable Positioning Option Verification Method Maintenance Consideration
1. Select the Positioning Architecture
Select Load and thrust Define moving mass, external force, acceleration, friction, and a safety factor. A practical preliminary design commonly uses a 1.5–2.0 safety factor for calculated continuous load. Ball-screw or belt-driven electric stages for controlled motion; pneumatic cylinders where end-position control and high force are more important than fine positioning. Measure the actual load profile with a force or torque sensor and confirm motor, screw, coupling, and bearing ratings. Inspect mounting hardware, couplings, and bearings for looseness or abnormal wear during scheduled service.
Select Positioning accuracy and repeatability Typical target ranges: approximately ±0.005–0.05 mm for a properly configured servo ball-screw axis; ±0.05–0.20 mm for many stepper screw systems; approximately ±0.1–1.0 mm for basic pneumatic stop arrangements. Servo motor with ball screw for high accuracy; stepper motor with lead screw for moderate accuracy; pneumatic positioning for less demanding end-point applications. Use a calibrated laser interferometer, dial indicator, or linear encoder. Record bidirectional repeatability, backlash, and positioning error over the full travel. Check backlash, screw wear, guide preload, and encoder feedback. Recalibrate after mechanical replacement or a major impact.
Select Travel and speed Match stroke, cycle time, acceleration, and duty cycle. Typical linear speeds range from about 0.01–0.20 m/s for screw-driven stepper systems and 0.10–1.00 m/s for many servo-driven systems, depending on design. Ball screw for high thrust and precision; timing belt for longer travel and higher speed; voice-coil actuator for short-stroke, high-dynamic motion. Run the complete motion profile at normal and maximum intended speed. Check settling time, overshoot, vibration, and motor temperature. Inspect belts for tension and wear; verify screw lubrication; check guide rails for contamination and uneven resistance.
Select Duty cycle and thermal load Calculate average and peak power from force, speed, acceleration, and cycle frequency. Continuous operation requires thermal capacity for the motor, drive, gearbox, and braking components. Servo systems with correctly sized drives for variable loads; electric actuators with thermal monitoring for repeated cycles; pneumatic systems where compressed-air consumption is acceptable. Operate the system through the longest expected production cycle and measure motor winding, drive, bearing, and enclosure temperatures. Keep cooling paths clear, inspect fans and filters, and review temperature trends for gradual increases that may indicate friction or overload.
Select Environment and protection Specify dust, moisture, washdown, temperature, vibration, and chemical exposure. The required enclosure rating must be selected for the actual installation environment. Sealed electric actuators for dusty or wet areas; pneumatic components for selected hazardous or washdown applications; protected guides and cable carriers for contaminated environments. Perform ingress, temperature, vibration, and contamination checks based on the applicable equipment specification and site conditions. Replace damaged seals, clean exposed guides, inspect cable jackets, and prevent contaminants from entering screw or bearing surfaces.
Select Feedback and safety Choose open-loop or closed-loop control according to the consequences of missed steps, drift, or incorrect positioning. Include limits, homing, emergency stopping, and guarding. Encoder-equipped servo or closed-loop stepper systems for position confirmation; limit switches and hard stops for basic travel protection. Test homing repeatability, limit switches, emergency-stop response, fault detection, and recovery after power interruption. Function-test safety devices at defined intervals and verify that sensors remain correctly aligned and securely mounted.
2. Test and Validate the Final Solution
Test No-load and full-load operation The system should complete the required travel without stalling, excessive vibration, unexpected noise, or control alarms. Use the selected actuator, transmission, guide system, drive, and controller as an integrated assembly rather than testing components only in isolation. Run no-load, nominal-load, peak-load, and representative production cycles. Compare current, force, position error, and cycle time against acceptance limits. Document baseline values so future changes in current, temperature, noise, or cycle time can be detected early.
Test Accuracy, repeatability, and backlash Validate performance in both travel directions and at several positions, including positions near the ends of travel. Closed-loop servo or encoder-based systems are generally preferred when bidirectional accuracy and drift control are critical. Measure at least ten repeated approaches from each direction at low, nominal, and high speed; calculate the spread and mean positioning error. Investigate increasing error before changing software compensation; mechanical wear, loose couplings, and contamination can cause recurring drift.
Test Endurance and failure recovery Test the expected production cycles plus reasonable margin, including controlled stops, power interruptions, overload events, and restart sequences. Include homing sensors, overload protection, braking, mechanical stops, and a defined recovery procedure in the final configuration. Record faults, recovery time, missed positions, component temperature, and maintenance actions throughout the endurance test. Use the results to set inspection intervals, spare-parts requirements, and replacement criteria.
3. Maintain and Improve the Positioning Solution
Maintain Lubrication and mechanical inspection Follow the component manufacturer’s lubricant type, quantity, and interval. Excess or incorrect lubricant can attract contamination or increase resistance. Ball screws, linear guides, gearboxes, and bearings require condition-based or scheduled inspection; belt systems require tension and alignment checks. Check friction, noise, temperature, backlash, vibration, and visible lubricant condition during planned maintenance. Use a maintenance log with date, operating hours, measured values, lubricant, and replaced parts.
Maintain Calibration and software settings Reconfirm coordinate scaling, homing offsets, acceleration limits, travel limits, and compensation values after mechanical or electrical changes. Encoder-based systems support ongoing position monitoring; open-loop systems need additional checks for missed steps and mechanical drift. Compare measured positions with a calibrated reference at defined points across the travel range. Back up controller parameters and record every calibration change to maintain traceability.
Maintain Spare parts and lifecycle planning Identify wear items and components with long procurement times, such as belts, seals, bearings, couplings, sensors, drives, and cables. Choose standardized, serviceable components where possible without compromising the required performance or environmental protection. Review failure history, mean time between failures, downtime, and repair time at regular intervals. Keep critical spares protected from moisture, dust, vibration, and electrostatic discharge, and define replacement thresholds.
Maintain Final acceptance criteria Define measurable limits for accuracy, repeatability, speed, cycle time, load, noise, temperature, safety, and energy use before production release. The final solution should meet the most restrictive requirement with adequate margin, not merely achieve nominal performance during a short demonstration. Issue an acceptance report containing test conditions, instruments, measured results, deviations, corrective actions, and approval records. Repeat the critical acceptance tests after major maintenance, relocation, collision, control upgrades, or changes to the payload.
Engineering note: The performance ranges shown are typical planning values, not guaranteed specifications. Final selection should be based on the actual payload, stroke, speed, duty cycle, environmental conditions, safety requirements, and verified test results for the complete positioning assembly.

FAQS

What are custom power positioning solutions?

They combine electrical power with controlled mechanical movement. Equipment can lift, lower, tilt, slide, or rotate. These systems match specific loads, dimensions, workspaces, and operating cycles.

Which functions are central to these systems?

Core functions include power conversion, motor control, motion synchronization, and safety monitoring. Sensors confirm actual position. Limit switches stop movement at defined endpoints. Overload protection helps prevent damage.

How should an actuator type be selected?

Linear actuators suit lifting, pushing, and tilting. Rotary actuators suit shafts moving through set angles. Screw-driven systems offer accurate movement but may be slow. Belt or gear systems can move faster, with possible backlash.

When is closed-loop control useful?

Closed-loop control checks actual position through feedback. It improves repeatability when friction or load conditions change. Timing-only systems can drift. I have seen that happen.

What safety features should the control system include?

Useful features include limit switches, overload protection, emergency stopping, soft starts, and manual override. Settings should match operator training and the machine’s risk assessment. Emergency stopping time should be tested.

How do AC and DC power options differ?

AC power suits fixed equipment with steady electrical access. DC power suits mobile platforms and battery-backed systems. Battery sizing should consider peak current, idle losses, recharge time, and cold temperatures.

What installation details can affect reliability?

Check cable routing, frame clearance, connectors, moisture exposure, vibration, and pinch points. Long cables may create voltage drop. I once underestimated it. The actuator stalled under load.

How can a system be tested before approval?

Test the complete assembly, not only the motor. Measure force, speed, noise, movement accuracy, and stopping time. Inspect brackets and platform balance. Drawings may miss slight twisting during lifting.

What maintenance features should a dependable solution provide?

It should include clear documentation, service access, verified safety functions, and measurable performance data. Leave space around adjustment points. A perfect specification becomes frustrating when technicians cannot reach the mechanism.

Conclusion

Choosing the right Custom power positioning solutions begins with understanding the system’s purpose and core functions. Start by defining the required load capacity, movement range, speed, accuracy, duty cycle, and installation environment. Consider whether the application needs linear or rotary motion, compact dimensions, adjustable mounting, or operation in demanding conditions. These requirements will help determine the most suitable actuator type, control method, feedback system, and power source.

A complete evaluation should also include positioning precision, operational safety, durability, noise, energy efficiency, and compatibility with existing equipment. The solution should integrate smoothly with controllers, sensors, software, and mechanical structures while allowing convenient monitoring and adjustment. Before final selection, test the system under realistic operating conditions to confirm performance and reliability. Regular inspection, cleaning, lubrication where appropriate, and timely replacement of worn components will help maintain stable operation and extend the service life of the positioning system.
Clara

Clara

Clara is a professional marketing specialist dedicated to helping businesses understand products, markets, and customers with greater clarity. With a strong command of the company’s solutions, she regularly creates and updates insightful blog articles for the company website, transforming complex......